J.Loc
Navigation without GPS
When GPS is jammed, spoofed, or lost, a drone drifts with the wind and can crash. J.Loc compares live camera images with satellite maps stored on board and gives the drone its position.
Why J.Loc?
Robust image matching
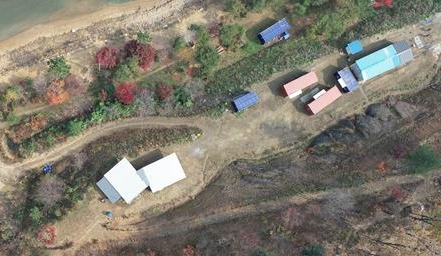
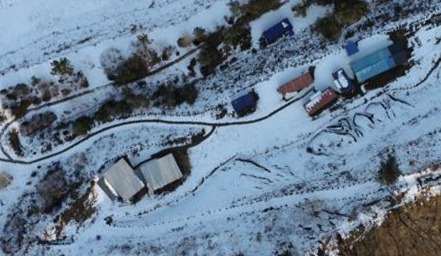
Satellite maps are usually taken long before the flight, and the ground changes with the time of day and the season. The AI image processing in J.Loc keeps stable features such as roads and buildings and ignores shadows and vegetation.
Low light
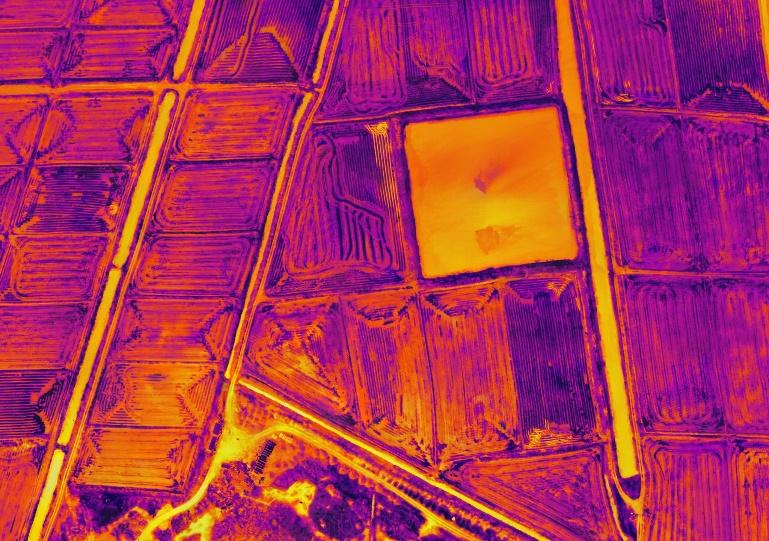
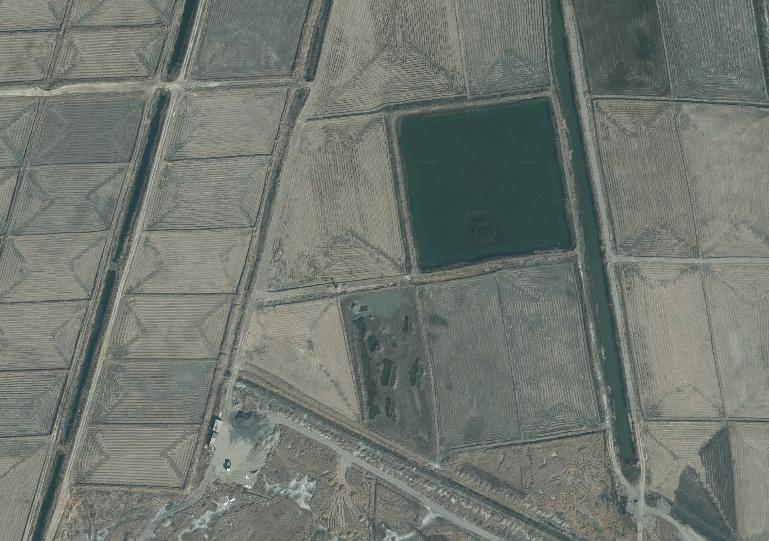
With a thermal (IR) camera, J.Loc also works at night by matching thermal images to the satellite map.
Proven in flight
J.Loc has been verified in flight tests with GPS jammers and GPS spoofers. In both cases, the drone kept flying stably on the J.Loc position.
Integration
J.Loc is installed between the GPS receiver and the flight controller. Normally it passes GPS data through unchanged while checking it against its own camera-based position. If the two differ by more than a set threshold, it treats GPS as faulty and sends its own position to the flight controller instead. It uses the standard GPS protocol, so no changes to the flight controller are needed.
Specifications
| Flight altitude | 30 m or more above ground |
| Output | Position and heading |
| Interface | Between GPS receiver and flight controller, GPS protocol (NMEA) |
| Processing | 10 Hz or more on an NPU (no GPU required) |
| Camera | Supplied camera module; thermal (IR) camera for night |
Get in touch
To ask about J.Loc, contact [email protected].